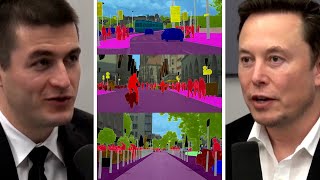
Short multi-speaker excerpt from a YouTube video discussion about autonomy (perception vs control). The participants argue that the hardest challenge is producing an accurate vector-space representation of physical objects from visual/sonar/radar inputs; once such representations exist, planning and control become relatively easier (analogy: video-game rendering such as Grand Theft Auto).
What's harder, perception or control for these problems. So being able to perfectly perceive everything or figuring out a plan once you perceive everything how to interact with all the agents in the environment in your sense from a learning perspective is perception or action harder in that giant beautiful multitask learning neural network.
The hardest thing is having accurate representation of the physical objects in vector space. So taking the visual input, primarily visual input, some sonar and radar and then creating an accurate vector space representation of the objects around you. Once you have an accurate vector space representation the planning and control is relatively easier, relatively easy. Basically once.
You have.
Accurate vector space representation then you're kind of like a video game like cars in Grand Theft Auto or something. They work pretty well. They drive down the road, they don't crash pretty much unless you crash into them. That's because they've got an accurate vector space representation of where the cars are and then they're rendering that.