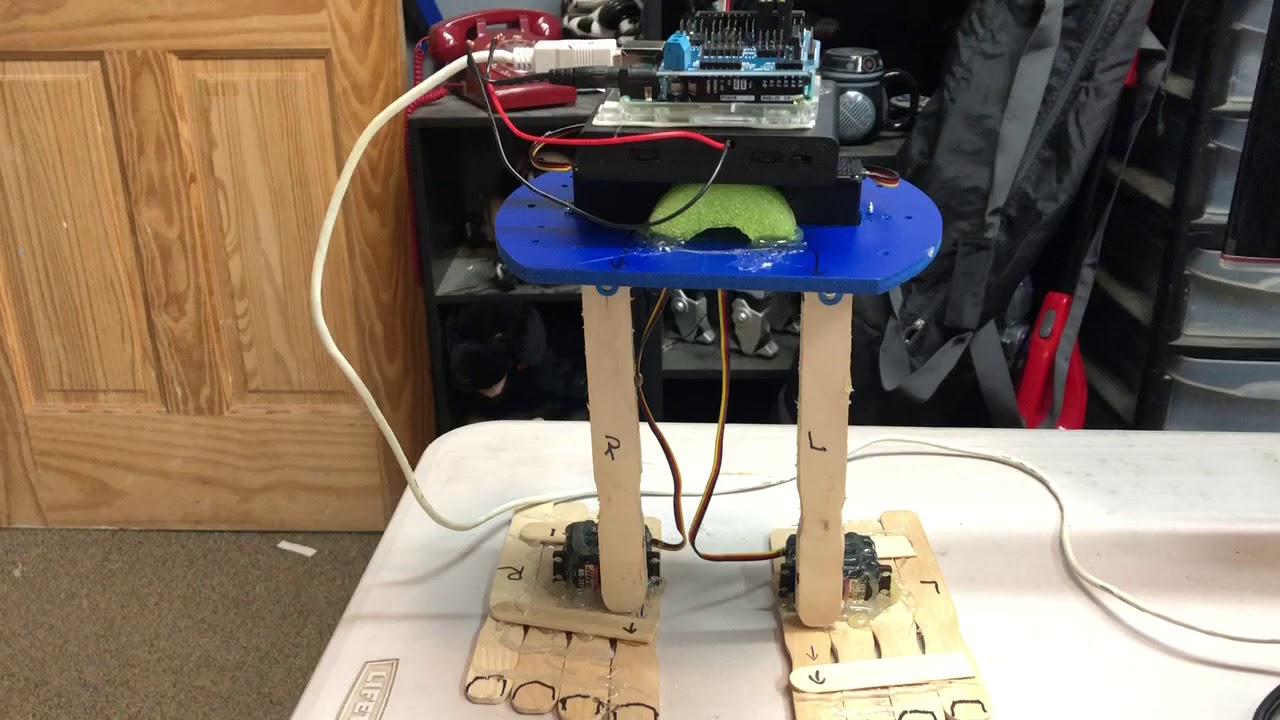
0:55
In this brief demo, the creator introduces the Barefoot Walker, a DIY robot modeled after the Otto platform using four servos and an Arduino. The robot currently lacks a distance sensor and a speaker/microphone, and its firmware only runs reliably when connected to a high‑amperage power source, meaning it cannot operate on its internal batteries. The presenter demonstrates the robot walking while noting these hardware and power constraints.
Chapters
More from Thomas

youtube.com
ROSie Part 2: Autonomous ROS 2 Smart Table Demonstration. LLM AI Chatbot, Vision, Voice I/O
6mo ago

youtube.com
Adam Savage - Bay Area Maker Faire : Sunday Sermon 2024 - 3 of 3 - #AdamSavage #BayArea #MakerFaire
2y ago




youtube.com
Singing Robot Betty9, Thomas Messerschmidt, Ghostbusters & @ Orange County Maker Faire 2023
3y ago