Crab Robot - EMT2461 Course Project - NYCCT-May 2014
27 May 2014 · 0 min
0:14
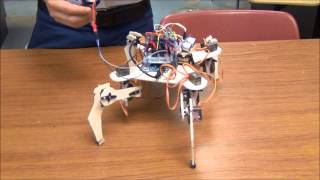
Richard Li and classmates built a wooden crab robot with 13 servos controlled by an Arduino Mega. It uses an ultrasonic sensor to detect obstacles and Bluetooth to communicate, turning to avoid things in its path.
More from Richard
youtube.com
Create Node-RED App on IBM Cloud to Send Alert Tweet Based on Data from an IoT Device (Part 2/2)
6y ago
youtube.com
Create Node-RED App on IBM Cloud to Send Alert Tweet Based on Data from an IoT Device (Part 1/2)
6y ago
See all content